π*0.6: four hours of robotic box assembling
Physical Intelligence · 2025-11-17 · demo · 4,337 views
What's in the video
Description written by Gemini, which watched and listened to the whole video.
Summary
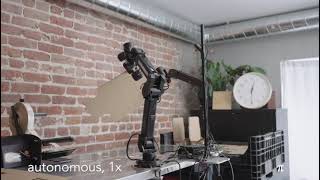
This video is an unedited, extended autonomous demonstration presented by Physical Intelligence (π), showcasing their robotic manipulation policy (identified in the title as π*0.6). Over an unbroken span of nearly four hours, a bimanual robotic arm system continuously and autonomously picks up flat cardboard sheets, folds and forms them into assembled boxes, and places them into storage bins.
What is shown
- Autonomous Bimanual Box Assembly: Two robotic arms mounted on a workshop table manipulate flat cardboard cutouts, coordinating both end-effectors to fold flaps, crease edges, and square the boxes into finished form [00:30–02:30].
- Continuous Multi-Hour Operation: The robotic system repeats the box-folding workflow continuously at 1x real-time speed across the multi-hour video without policy failure [00:00–230:10].
- Human-in-the-Loop Environment Maintenance: A human technician periodically enters the frame to remove stacks of assembled boxes from the bin and restock flattened cardboard sheets while the robot continues operating [26:15–26:50, 50:20–50:30, 77:35–77:45, 119:10–119:25, 133:35–134:10, 154:10–154:20].
Claims & numbers
- Runtime: Approximately four hours of continuous autonomous box assembling at real-time (1x) playback speed (indicated by on-screen overlay "autonomous, 1x" and the video title).
- Autonomous Execution: The folding policy operates fully autonomously without teleoperation during assembly cycles (indicated by on-screen overlay).
Notable quotes
- None (the video has no spoken dialogue, narration, or voiceover).
Assessment
This is a real, unedited long-duration endurance demo of physical AI manipulation from Physical Intelligence. The entire multi-hour run is shown in continuous real-time without cuts or speed-ups, demonstrating robust generalization and long-horizon bimanual dexterous manipulation.
Described by gemini-3.8-flash on 2026-09-29 from the video's audio and frames.